Uncertainty-Aware Digital Twins for Industry 4.0: A Metrology-Driven Conceptual Framework with a Healthcare Robotics Case Study
D Thakur, V Barbuto, C Savaglio, A Guzzo, G Fortino
Abstract
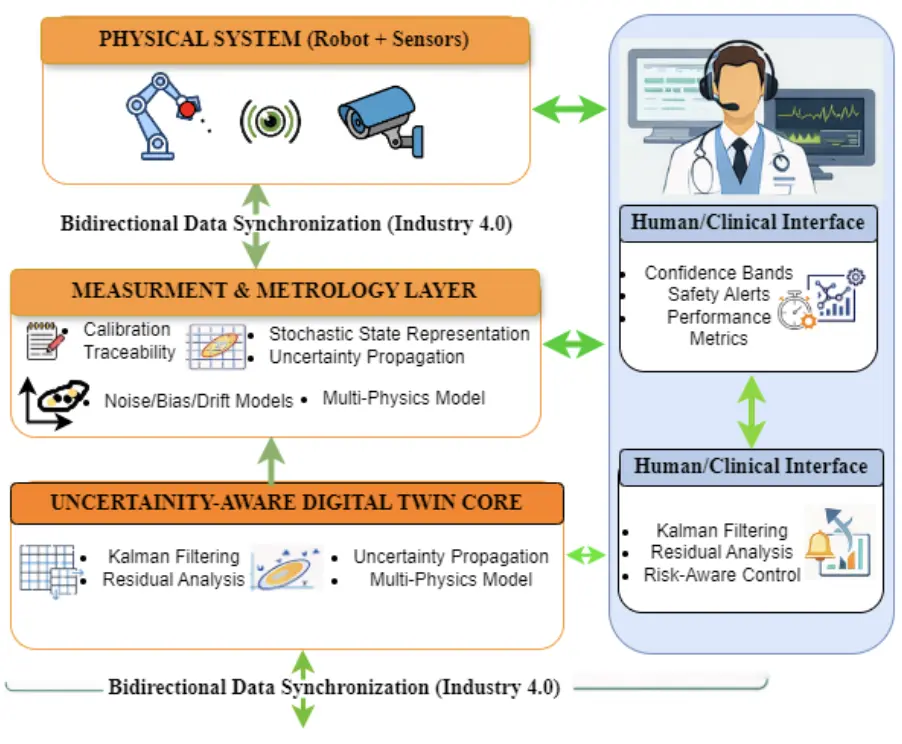
Digital twins have emerged as a key enabling technology in Industry 4.0, enabling virtual representations of physical systems that evolve in real time through data synchronization. They are widely applied to industrial robotic systems such as manipulators, collaborative robots, and automated production cells for applications including process monitoring, predictive maintenance, and control optimization. Despite their growing adoption, many existing digital twin implementations implicitly assume that sensor measurements are accurate and reliable. In practice, measurements of key variables such as position, velocity, force, and system states are affected by uncertainty arising from noise, bias, drift, and environmental disturbances, which can significantly impact the reliability of digital twin predictions. This paper proposes a metrology-driven conceptual framework for uncertainty-aware digital twins (UA-DTs), integrating measurement uncertainty into the digital twin lifecycle to ensure trustworthy monitoring and control, exemplified through a healthcare robotics case study.